MR Clutch Actuator for a Robotic Hand
A miniaturized planetary-gear magnetorheological (MR) clutch that acts as the per-joint actuator in a fully actuated multi-finger robotic hand. MR fluid gives controllable, smooth torque transfer from a shared motor. The work builds on the squeeze-mode MR clutch concept introduced by Sergey Pisetskiy and Mehrdad R. Kermani at Western; I led the redesign that took it from a failing prototype toward fabrication.
- Sheet
- 01
- Context
- ARM Lab research
- Period
- May 2026 - Present
- Shaft
- Ø1 → Ø2 mm
- Coupling
- Keyway → D-profile
- Drawing std.
- ISO 2768-m
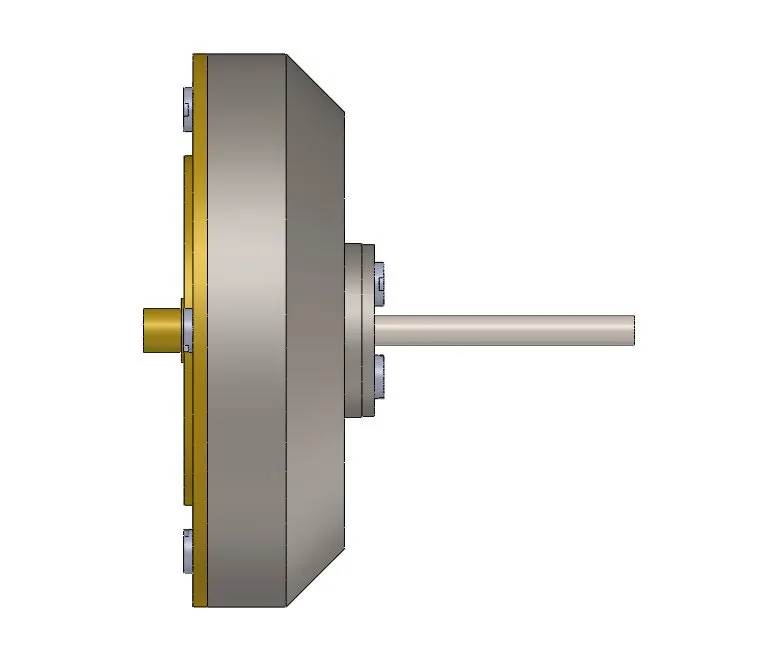
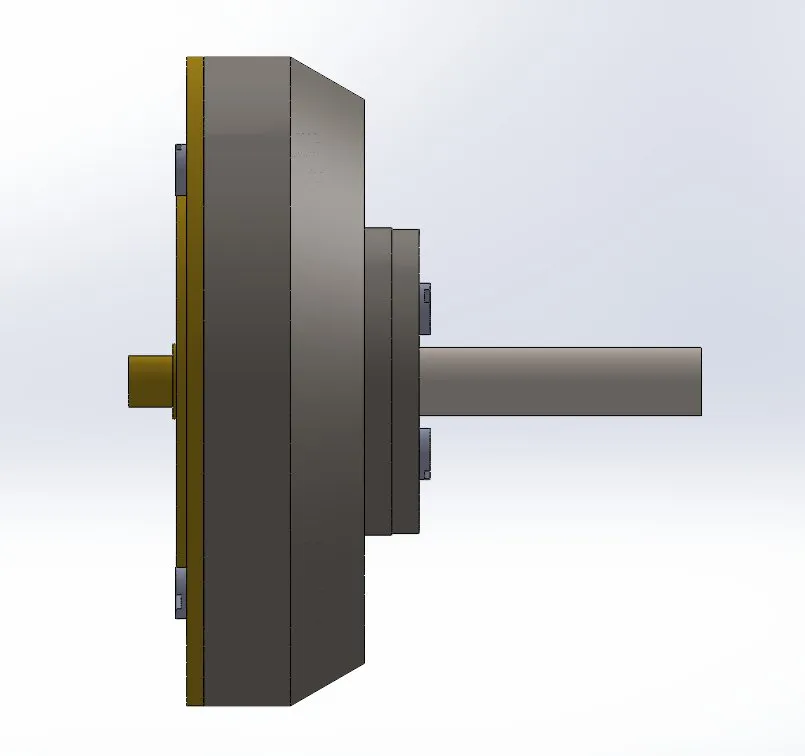
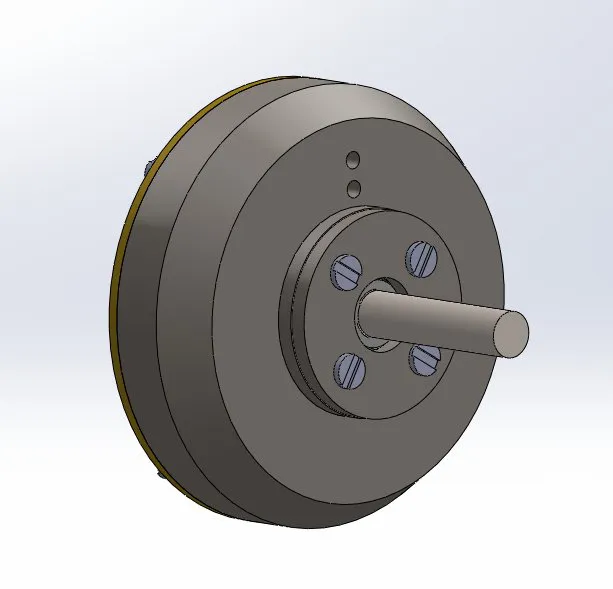
Exterior views only. Internal geometry is omitted because the lab's research is ongoing.
Builds on
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2020A Concept of a Miniaturized MR Clutch Utilizing MR Fluid in Squeeze ModeIntroduces a miniaturized MR clutch that uses a set of gears to work the MR fluid in squeeze mode, aimed at compact robotic joints such as gripper fingers. My redesign builds on this concept.Read the paper on IEEE Xplore What I did
- Traced the shaft fracture and the keyway problem to one shared stress-concentration root cause
- Upsized the shaft from 1 to 2 mm and replaced the keyway with a D-profile shaft/bore coupling
- Relocated the electromagnetic coil radially outward while keeping torque, since magnetomotive force N·I does not depend on coil radius, and kept the steel section that carries the flux
- Produced the full manufacturing drawing set under ISO 2768-m; caught and fixed a bearing-seat fit error in design review
- Ran sourcing across five manufacturing platforms
Results
- Both failure modes addressed with a single design change
- Approved quotes secured for the primary parts
- Design moving to fabrication for the hand prototype