Humanoid Neck Mechanism
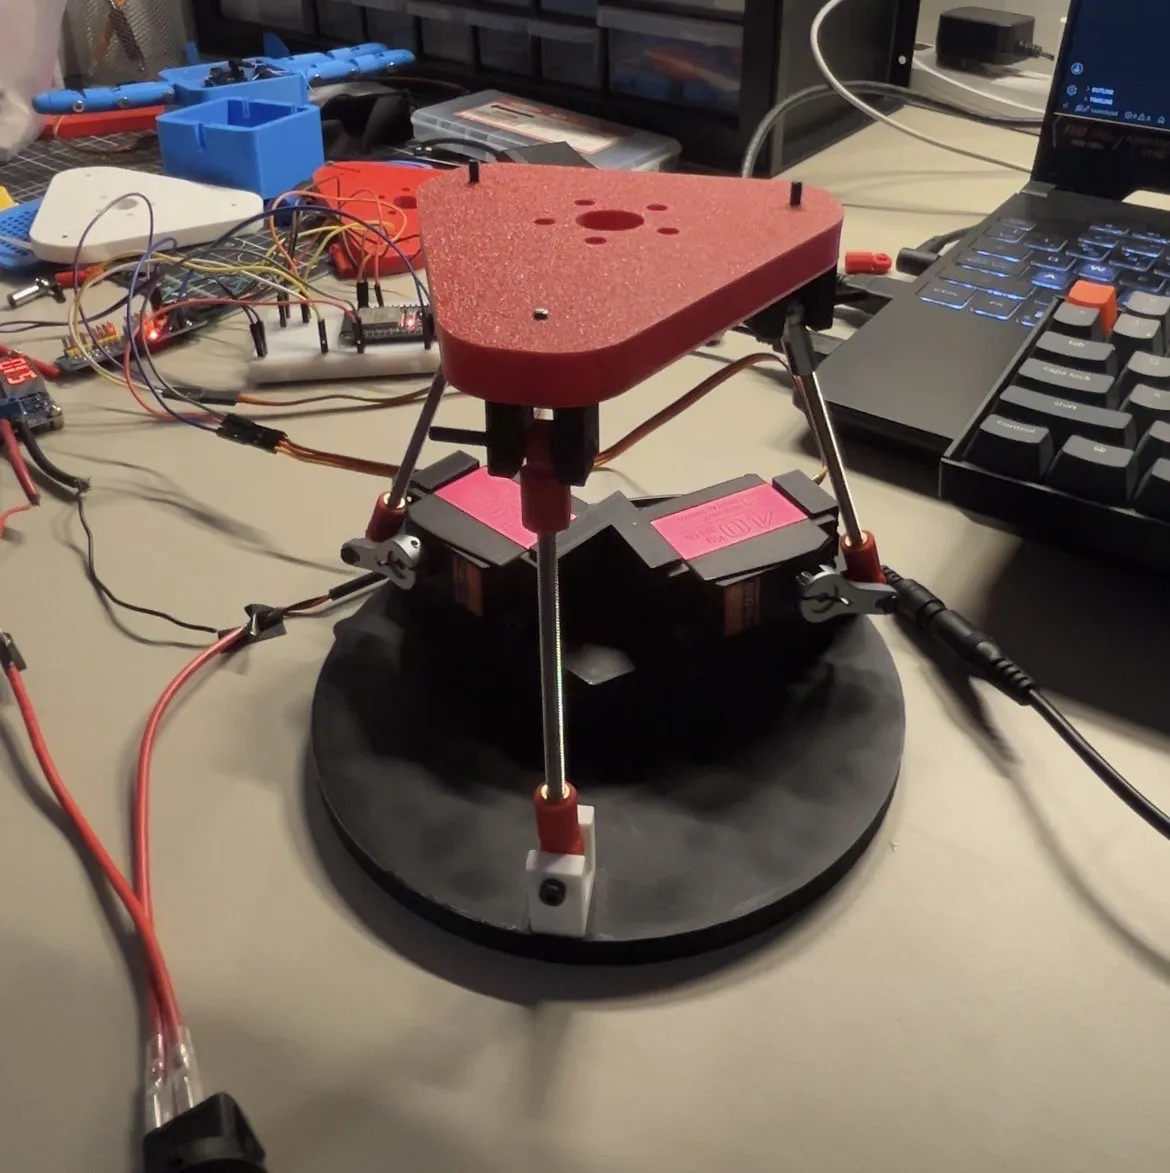
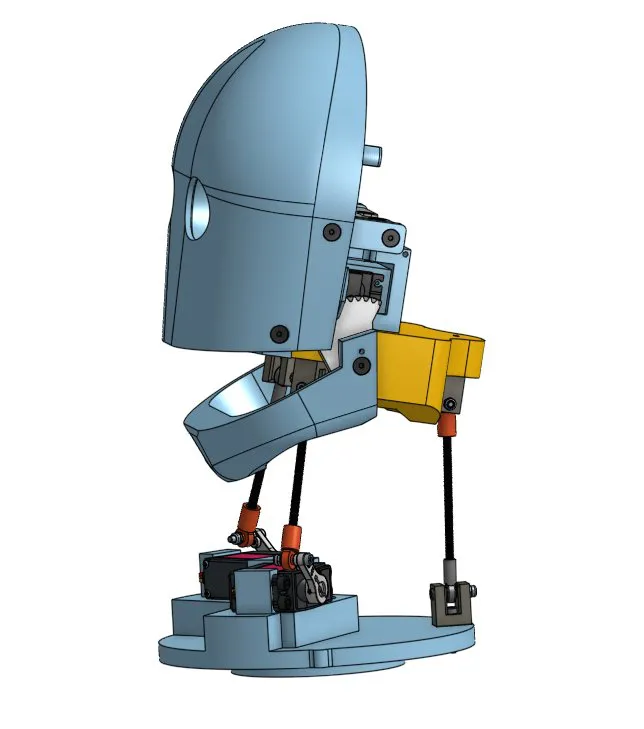
The neck for Baker Bot, a torso-up humanoid lecture-assistant robot built by the WE First club. Two servos drive ball-jointed pushrods against a fixed-length rear link, so the head can nod (pitch) and tilt sideways (roll) like a person's. I owned it from first idea to the part on the robot.
- Sheet
- 02
- Context
- Baker Bot · WE First Club
- Period
- Summer 2026
- DOF
- 2 (pitch, roll)
- Actuation
- 2 × 40 kg servo
- Linkage
- 2-DOF parallel
Neck assembly in 3D
Drag to orbit. Click, then scroll to zoom.
Exported from Onshape and simplified for the web.
What I did
- Came up with the 2-DOF linkage: two angled 40 kg servos driving pushrods, with a fixed-length rod at the back as the pivot and stabilizer. Moving the servos together pitches the head; moving them differentially rolls it
- Modelled the mechanism in Onshape using off-the-shelf rod ends and custom 3D-printed mounts
- Built a standalone bench prototype to prove out the linkage before touching the head
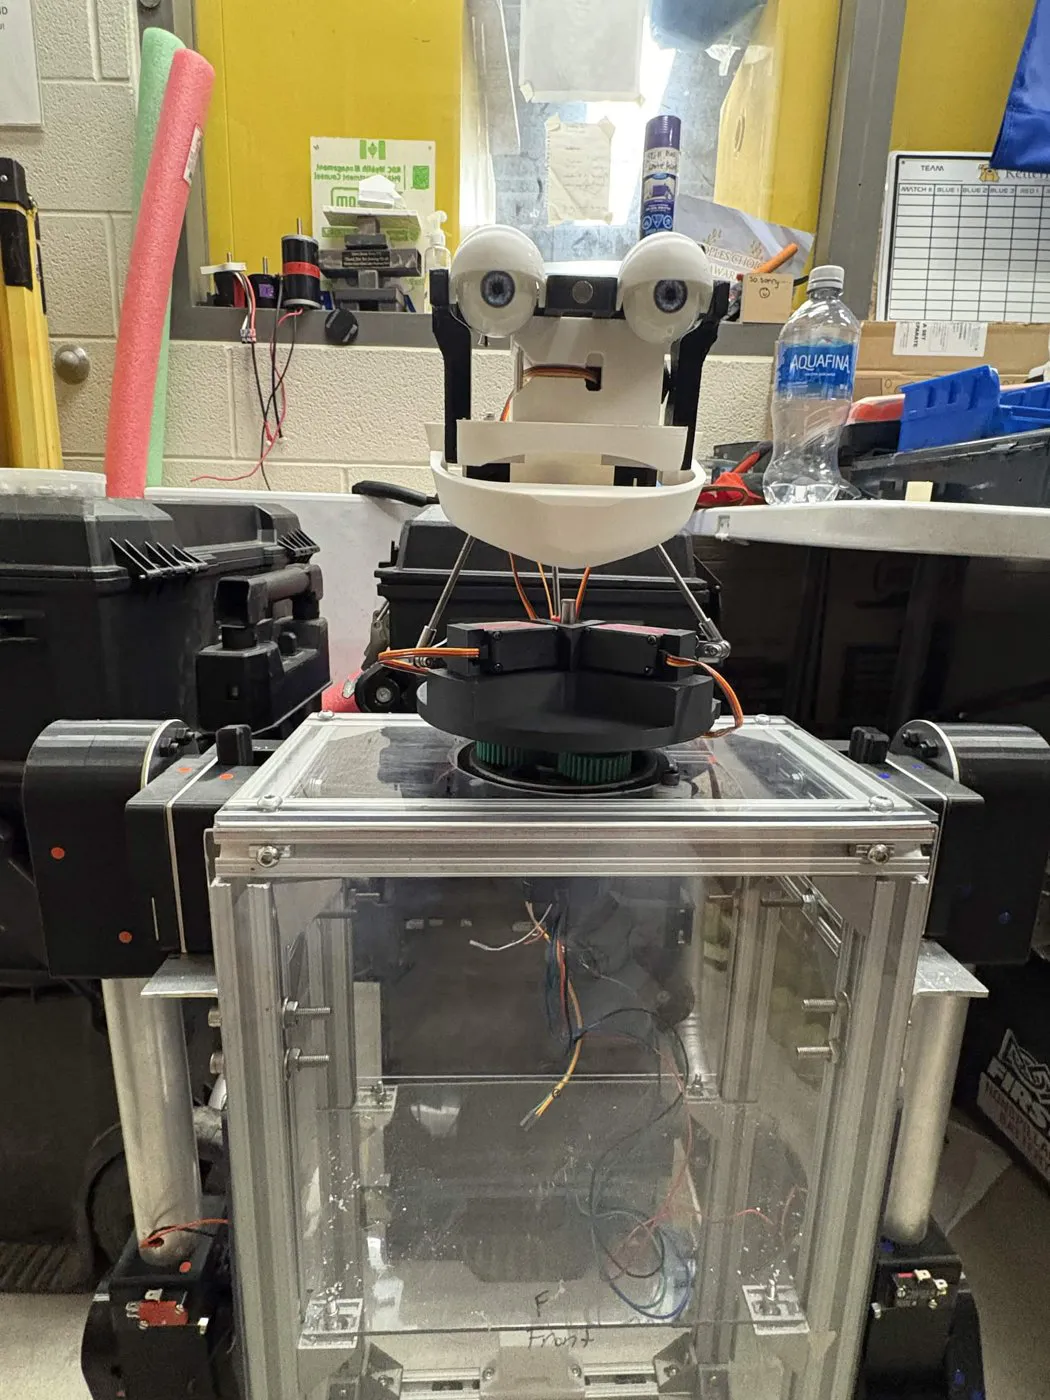
- Manufactured the final version and adapted the mounts to the head geometry
- Coordinated with the head and torso subteams on interfaces and integration
Results
- Linkage validated on the bench before integration; pitch motion tested on the final assembly
- Final neck mounted on the robot with the full head, and handed off to the software and torso teams